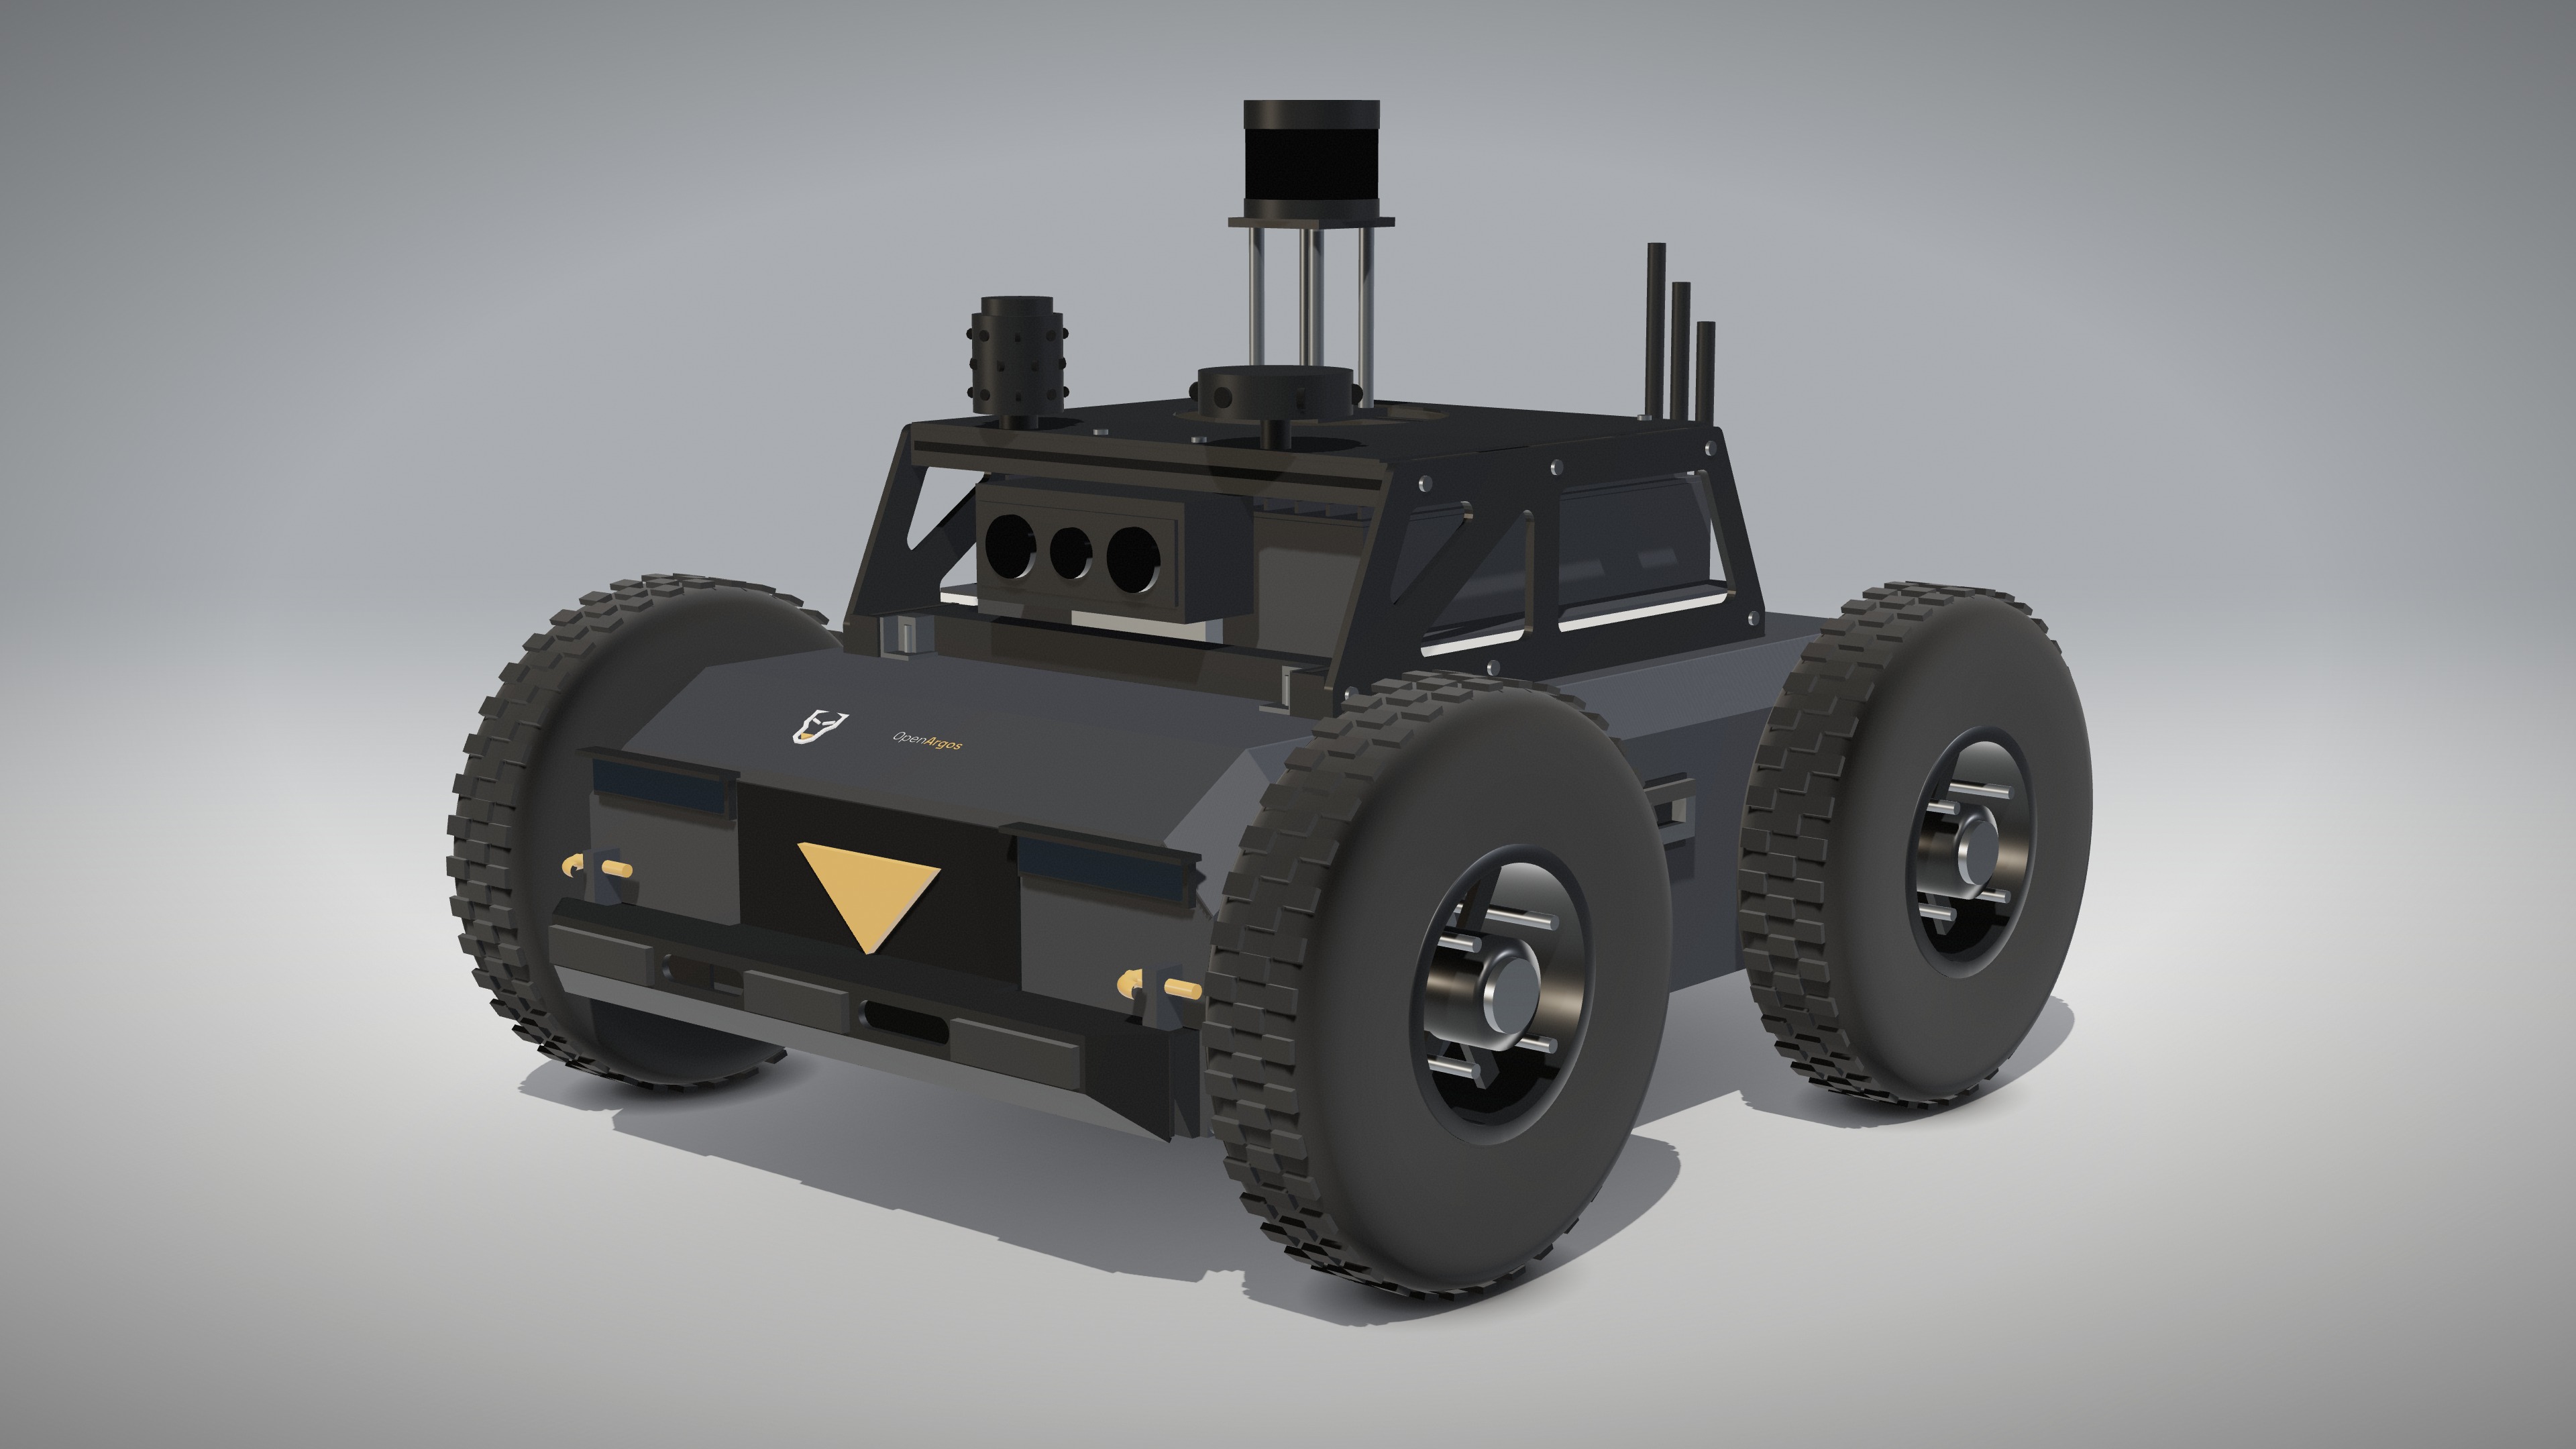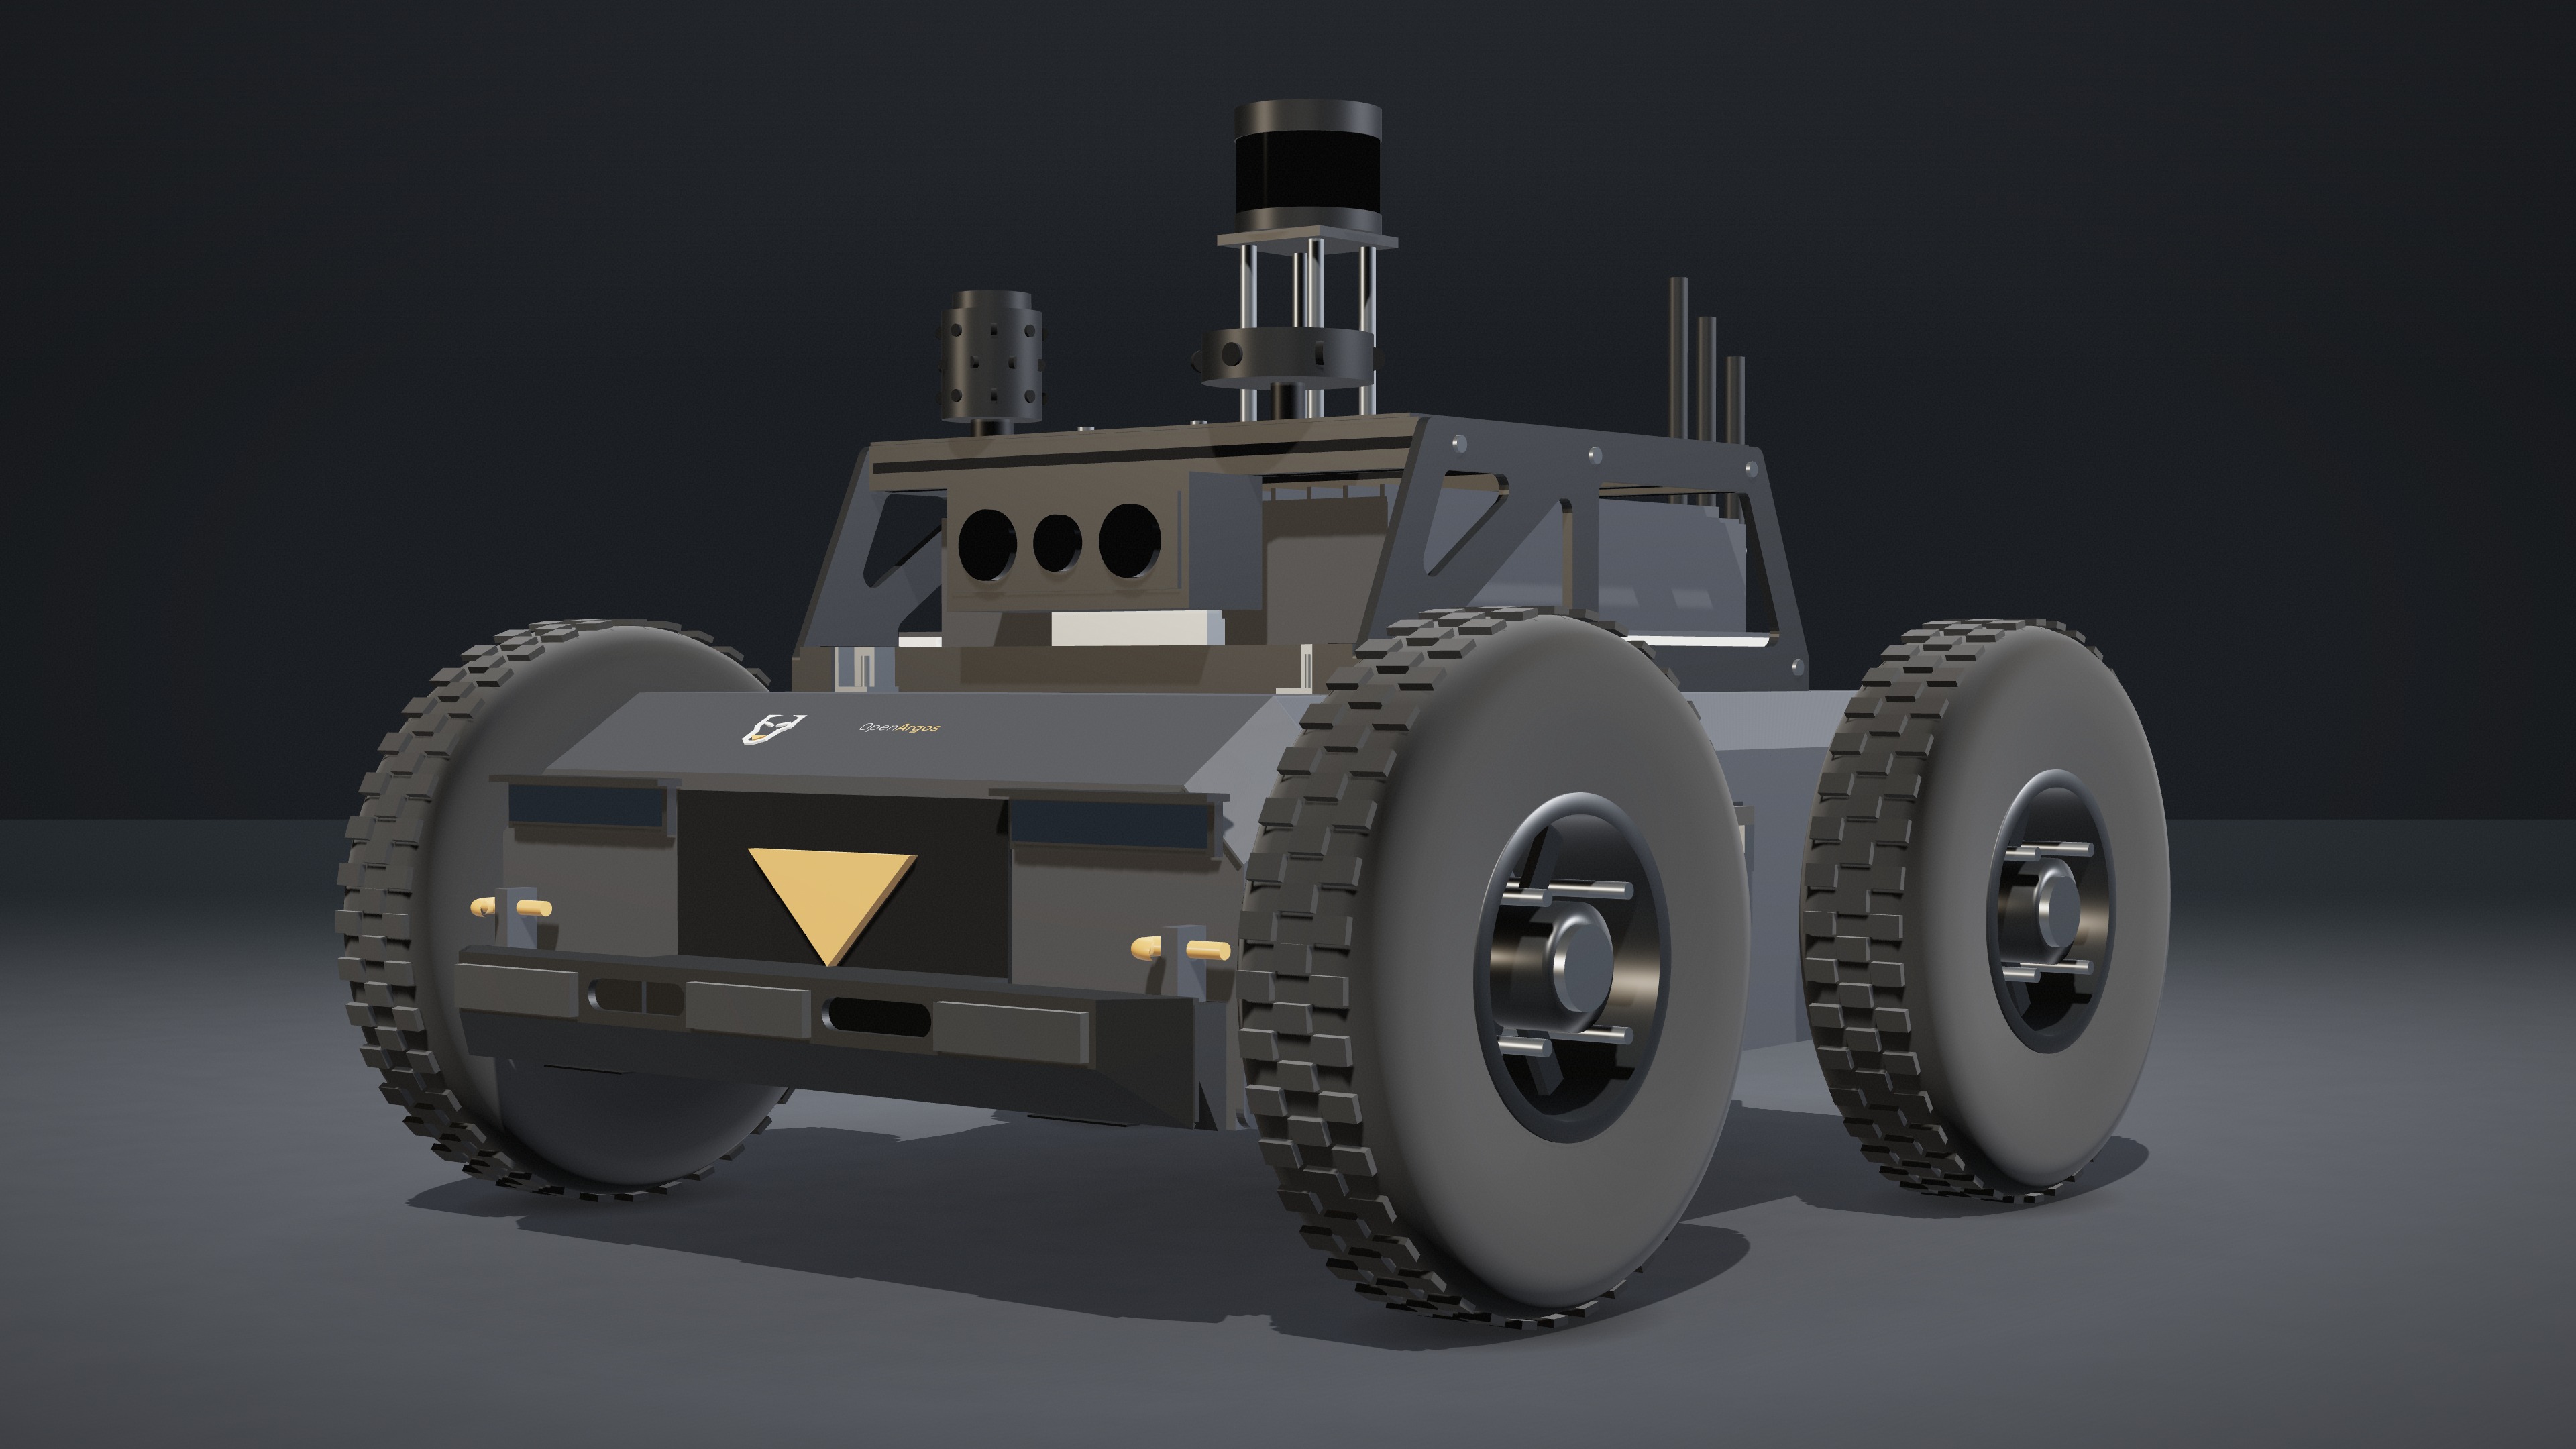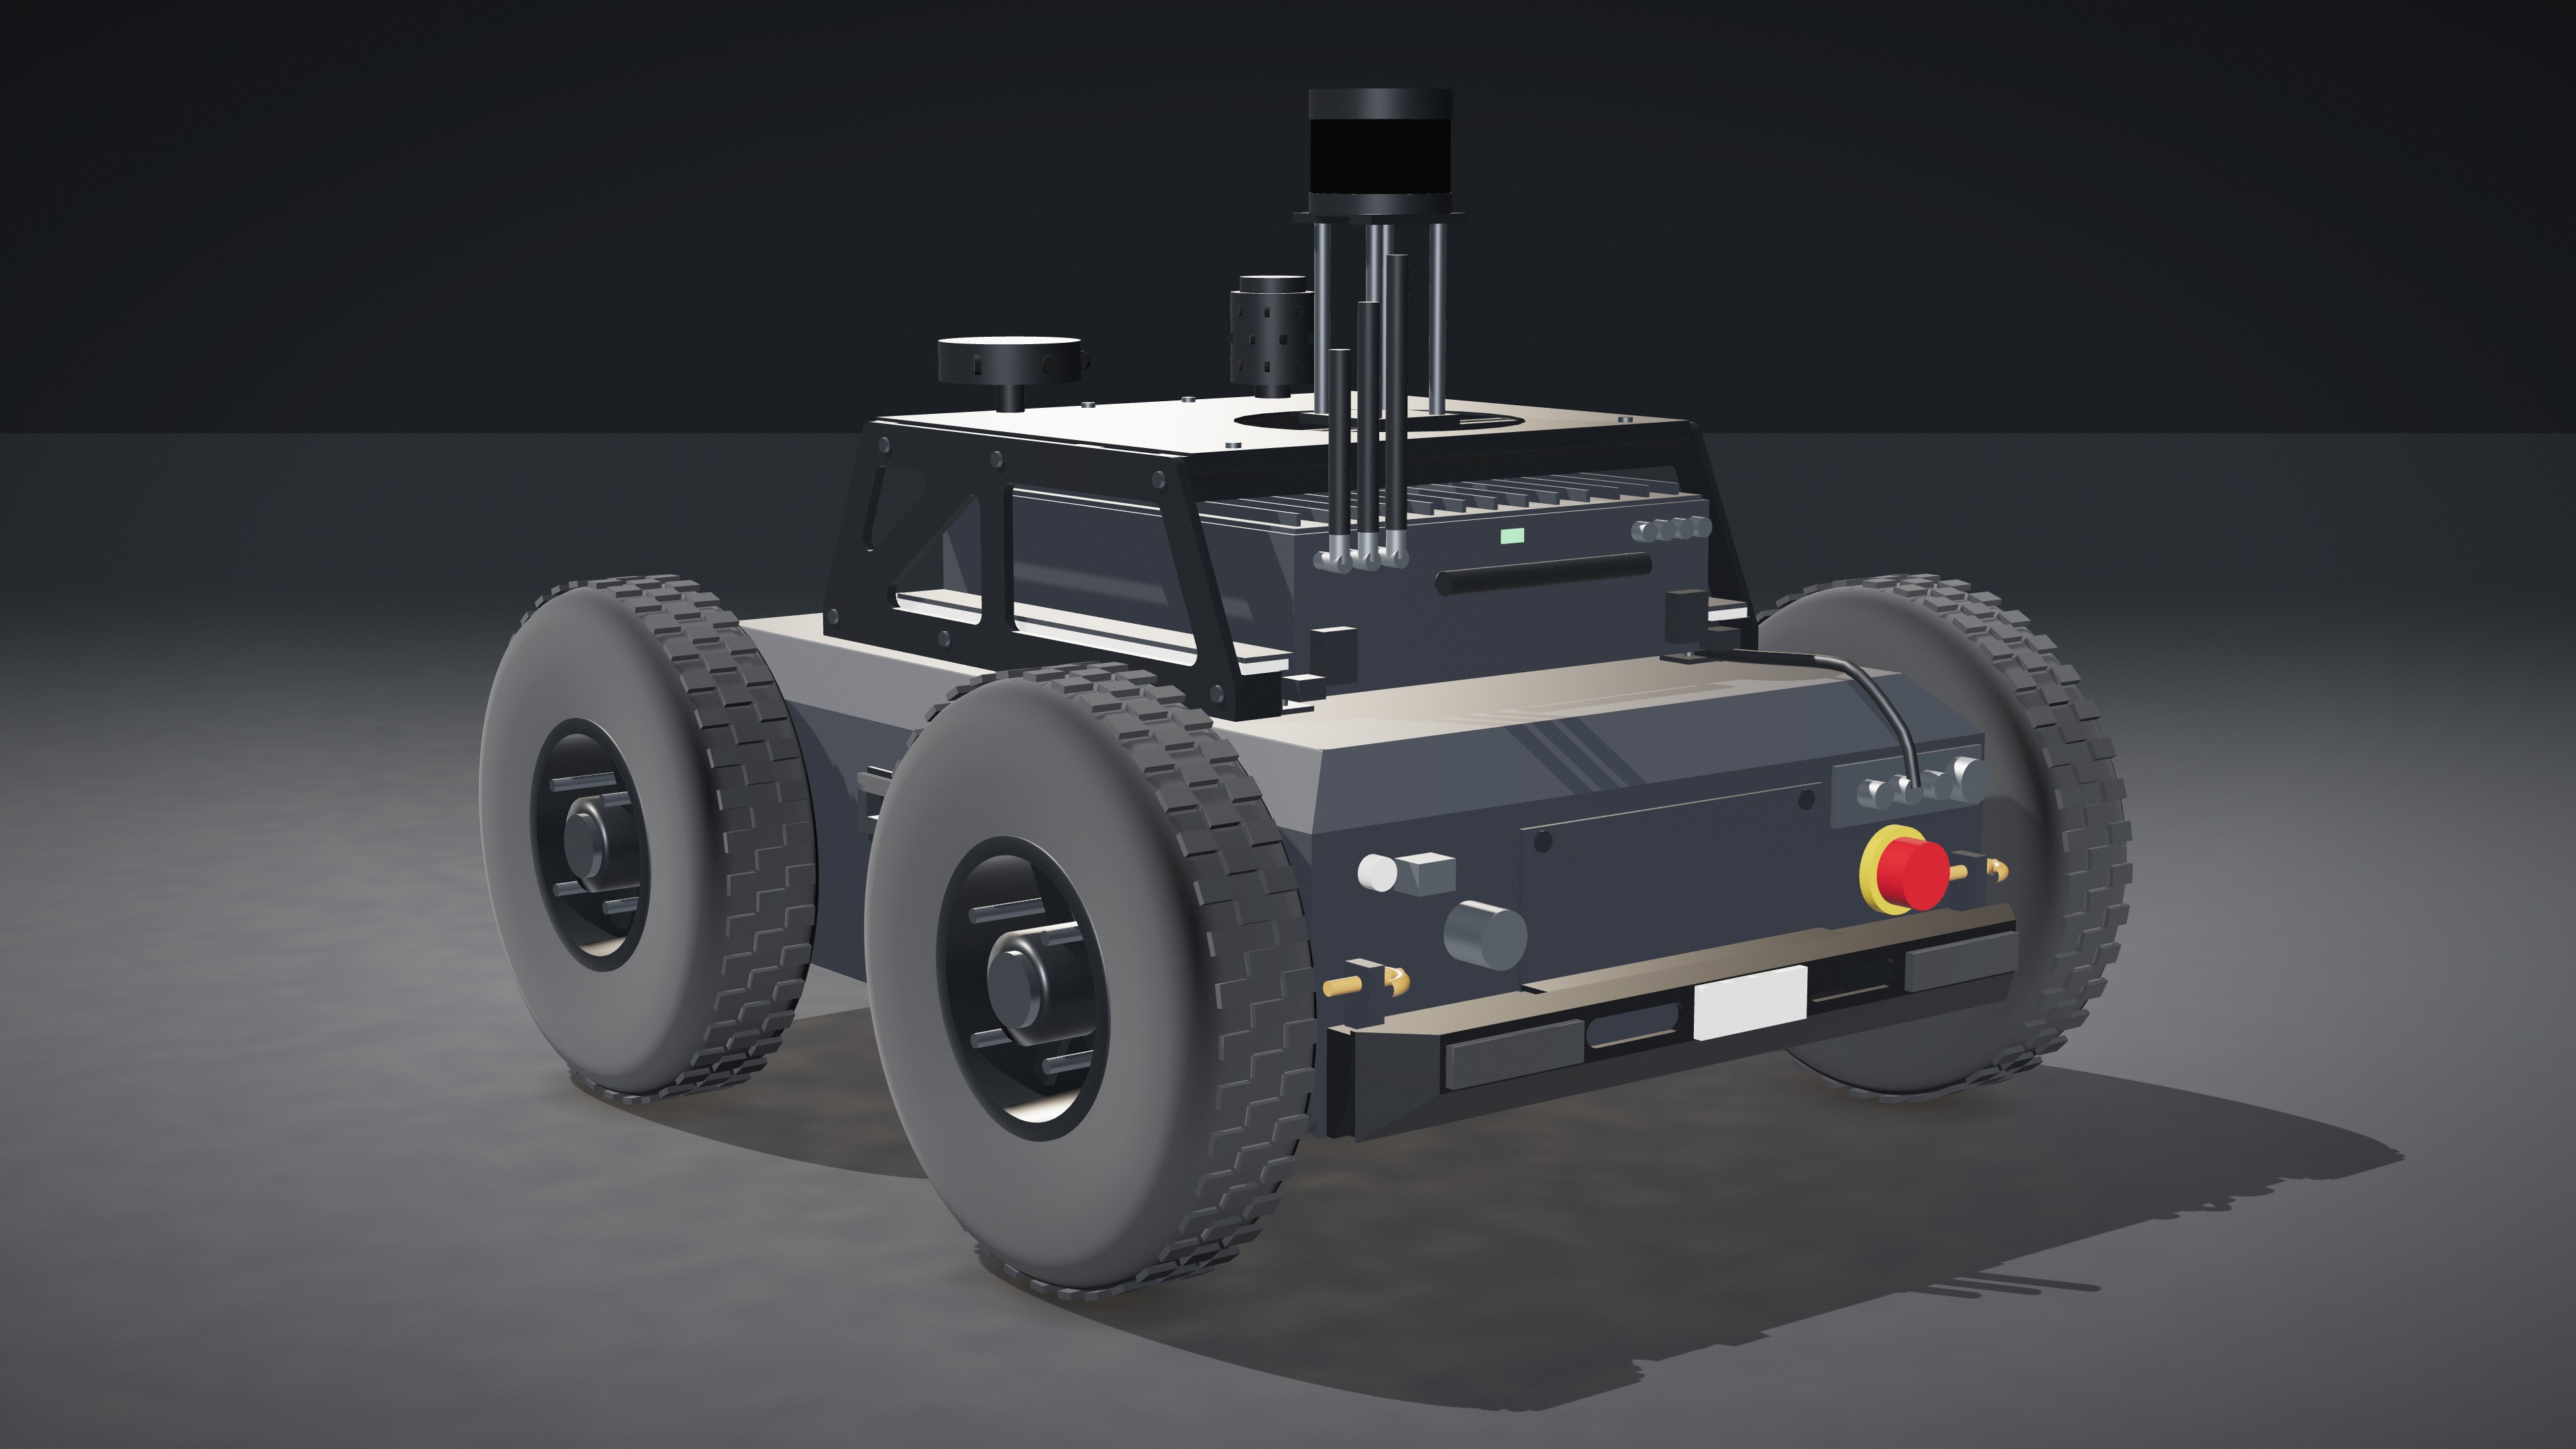
A skid-steer outdoor robot: a rigid aluminum box chassis, four gearmotors, a rear-loading battery cassette and a sensor cage with a slide-in payload enclosure. Everything here is the live design. The 3D models, the notes and the renders change as the design does.
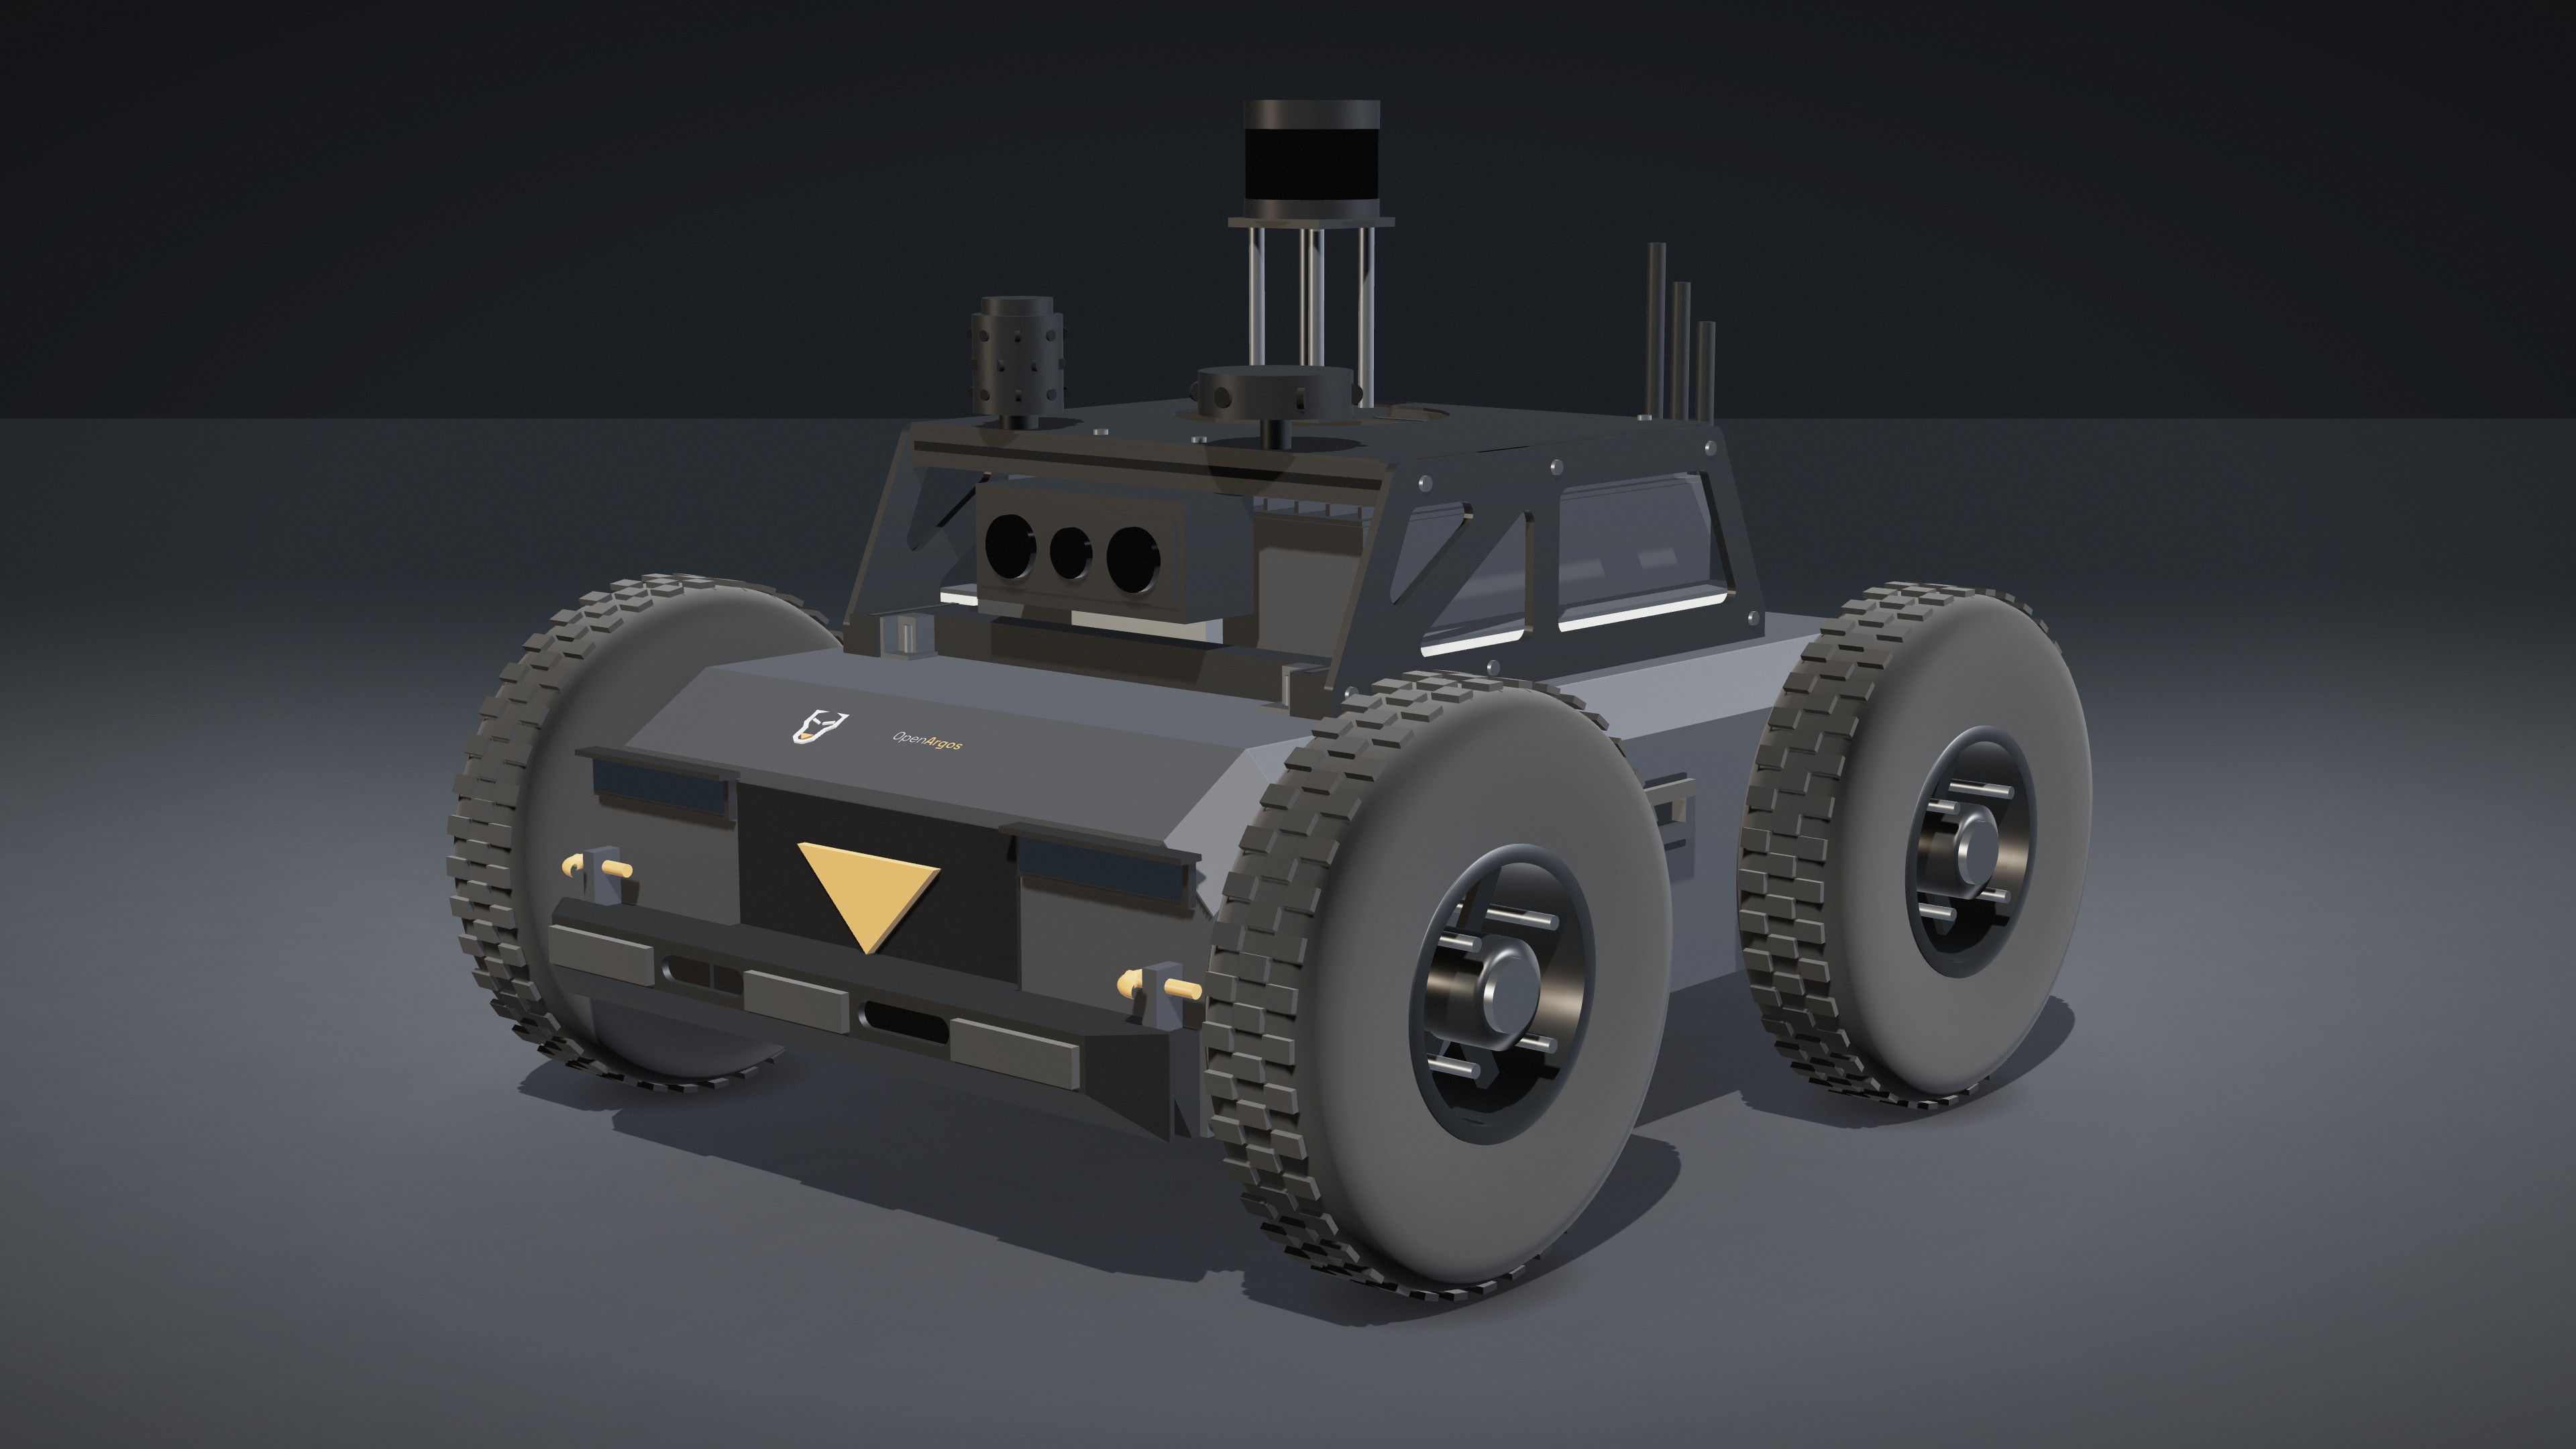
Rigid aluminum box chassisfour gearmotors, one per wheelrear-loading two-pack battery cassette (1440 Wh)485 mm wheelbase860 × 716 mm overall
Three interactive models
They run in the browser: drag to rotate, right-drag to pan, scroll to zoom, click a part for what it is and its key dimensions.
UGVThe robot: box chassis, drive, battery cassette, lights, bumpers and the sensor cage. Click any part for its specification.3D modelCagesHow the sensor cage attaches: rails, brackets, dock and latch keepers, with every fastener. Explode to see each one.3D model · partnersPayload EnclosureThe sealed electronics drawer that slides into the sensor cage and docks on one blind-mate connector.3D model · partners
Design notes
The full design, the power budget, the open questions for vendors, and the studio renders. These, the other two models and the renders gallery are for partners: they ask for the partner password once per browser.
Renders
Studio renders of the model, 3840 × 2160, for slides. Click one for the gallery.